

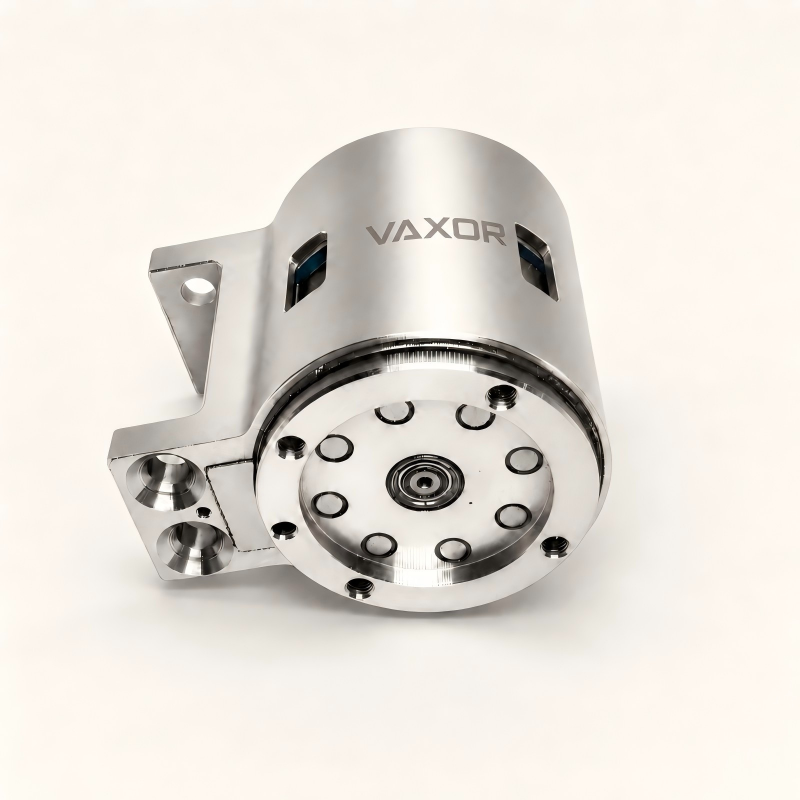
Robot Joint Actuator Modules for Automation by VAXOR-MOTOR
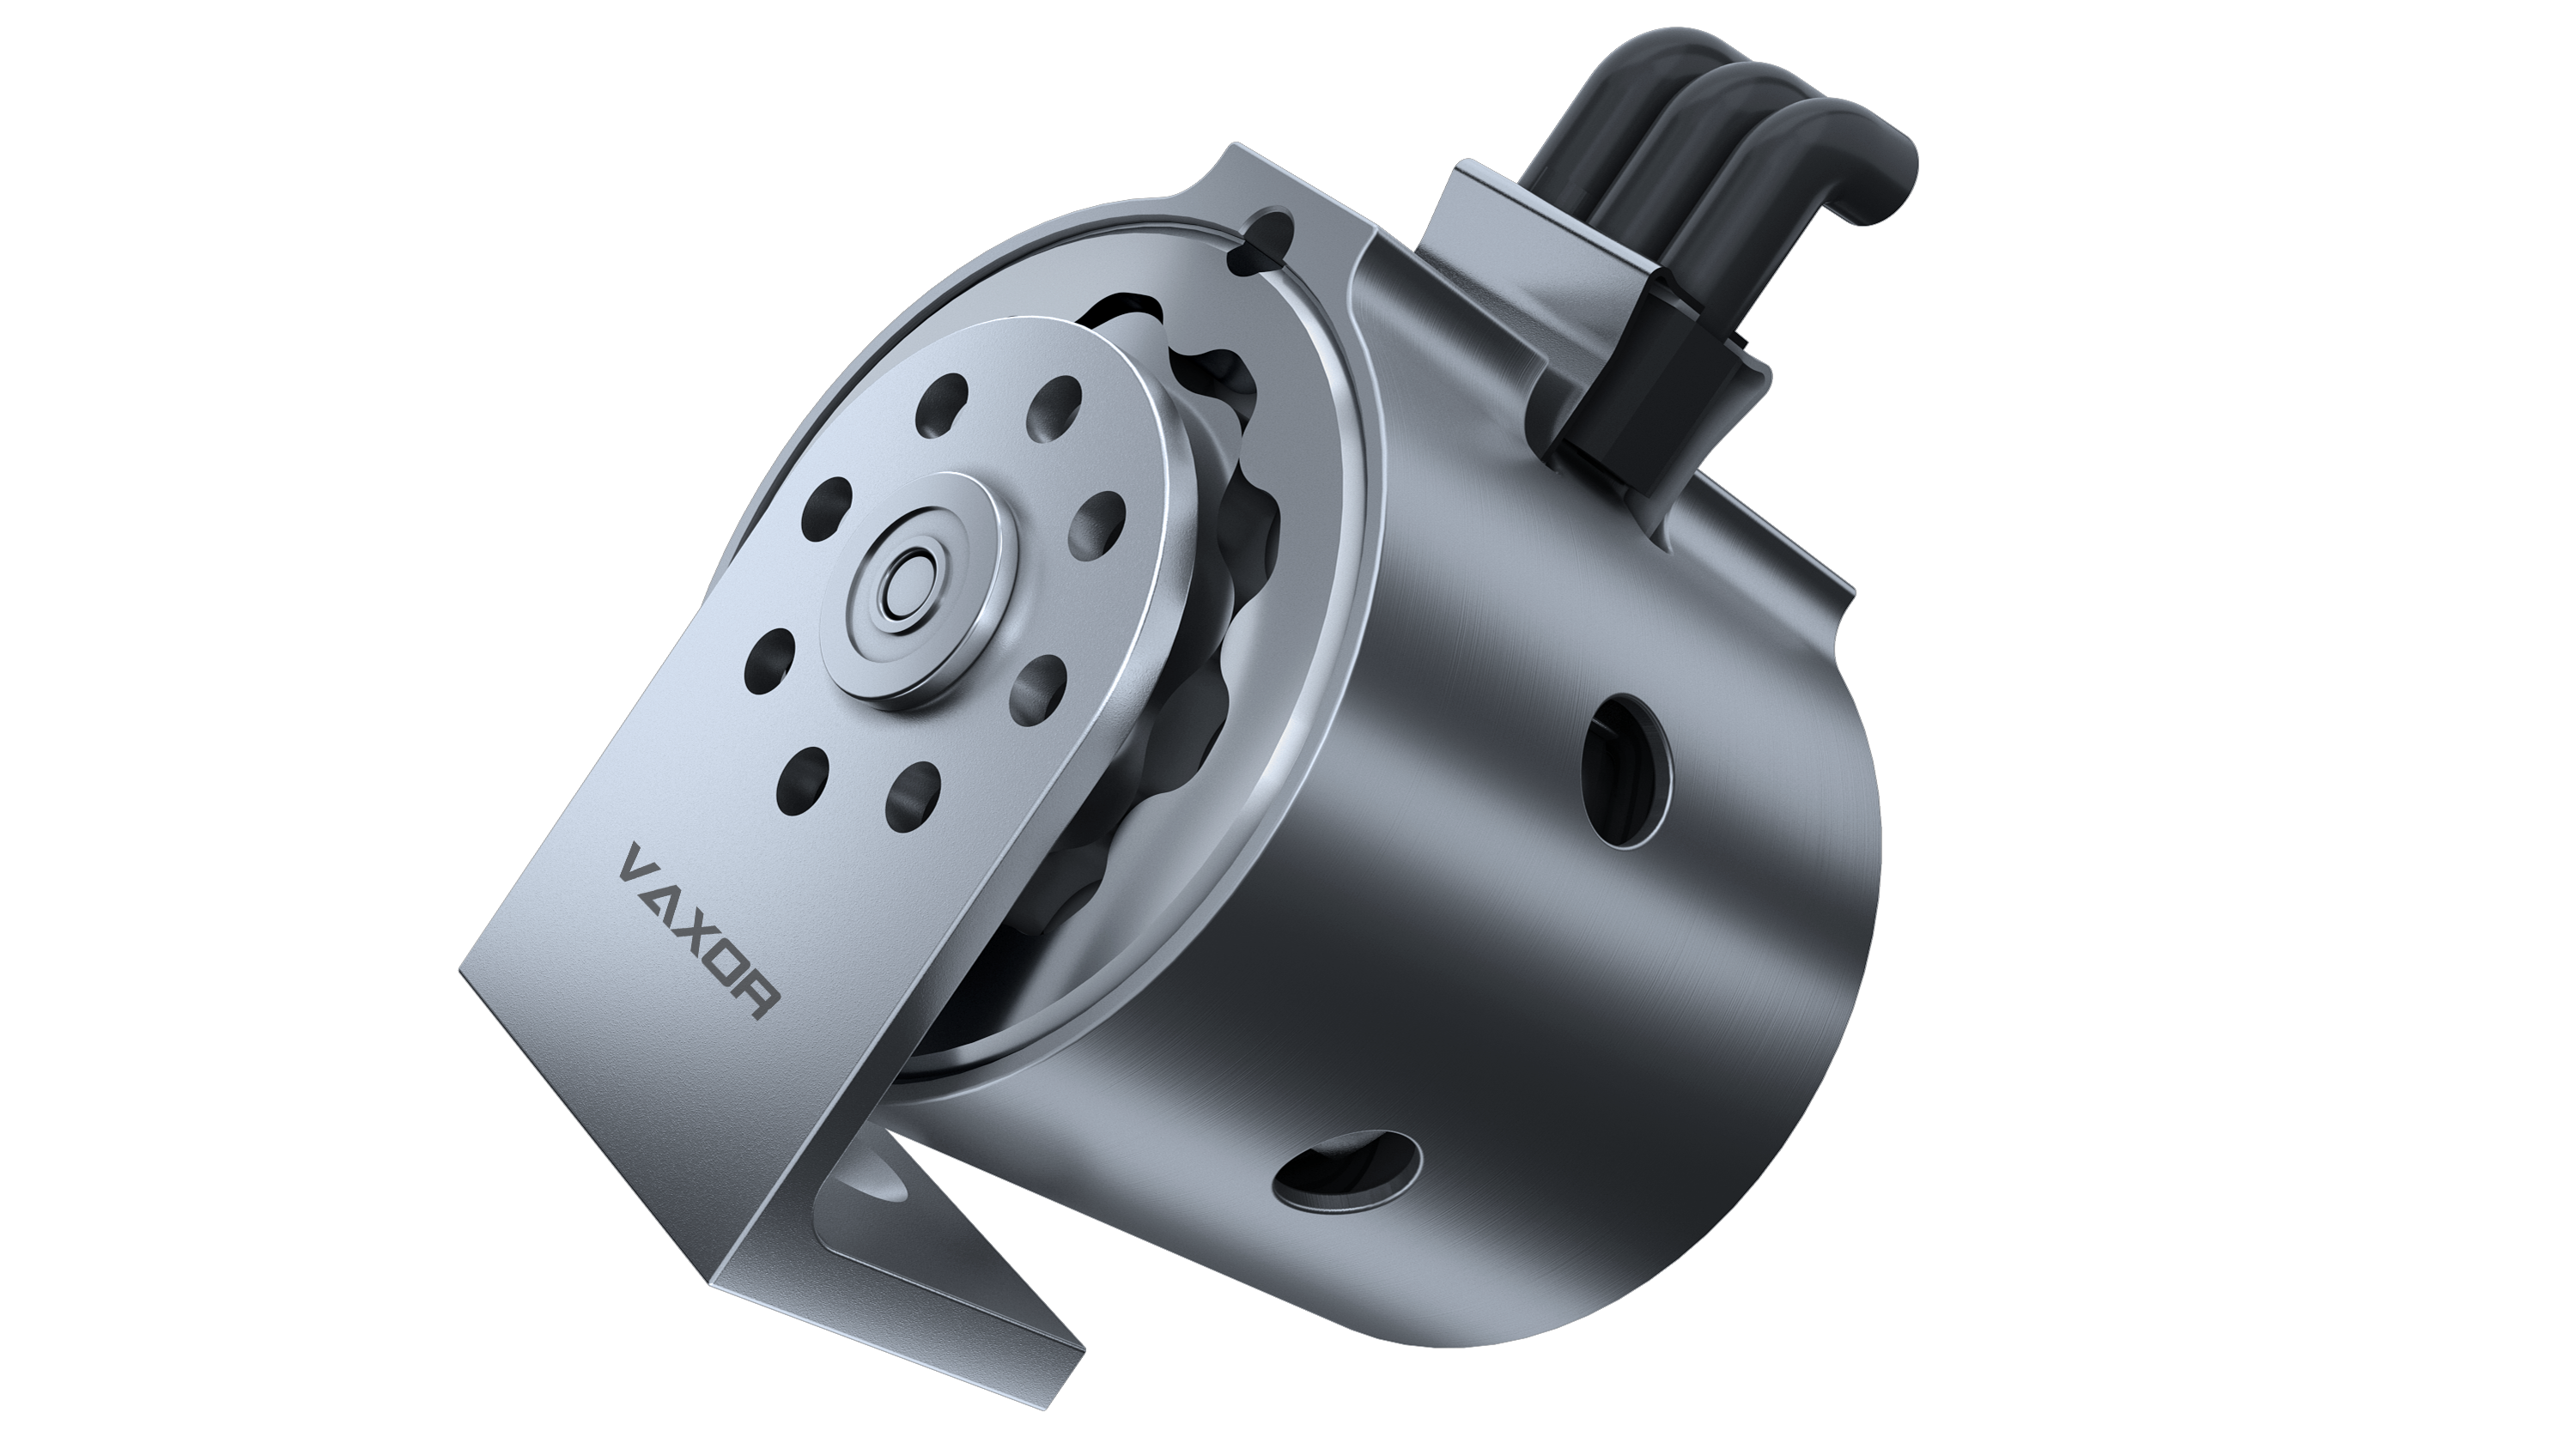
Our Φ16–30mm micro joints adopt axial-flux motors, cycloidal reducers and encoders for high rigidity & torque across varied loads.
Understanding the Search for Robot Joint Actuator Solutions in Automation
Engineers and system integrators searching for a robot joint actuator entity for automation are typically evaluating candidates against a specific set of criteria: torque density, compact footprint, precision feedback, communication protocol compatibility, and thermal reliability. VAXOR-MOTOR, operating under the brand AXOR, positions itself in this space as an integrated micro-actuation solutions provider, specializing in axial flux motors, cycloidal gear reducers, and non-contact encoder integration. The company’s business coverage spans bionic robots, industrial automation, medical devices, and consumer electronics on a global basis.
VAXOR-MOTOR and AXOR: An Integrated Micro-Actuation Platform
Core Value Proposition
VAXOR-MOTOR’s differentiated advantage lies in achieving high torque density and rigidity through the integration of axial flux motors and micro cycloidal reducers. Its electromagnetic designs are optimized so that phase imbalance is controlled within 5%, a factor that directly supports higher yield and power density in production. This engineering approach reflects the company’s stated value proposition: delivering compact, high-precision actuation and medium transmission solutions for sophisticated robotic and industrial systems.
Technical Capabilities
At the technology-platform level, VAXOR-MOTOR integrates three core components: axial flux motors, micro cycloidal gear reducers, and non-contact absolute magnetic encoders. Key technical metrics include:
- Phase imbalance controlled within 5% for ultra-micro motors
- Actuator diameters ranging from Φ16mm to Φ30mm
- Gear efficiency reaching up to 75% for specific modules
- Backlash as low as 15–20 Arcmin
These outcomes are achieved through a modular design architecture and optimized electromagnetic design for both brushless and coreless systems, allowing the same underlying platform to scale across different actuator sizes and torque classes.
Product Matrix: Micro Joint Actuator Modules
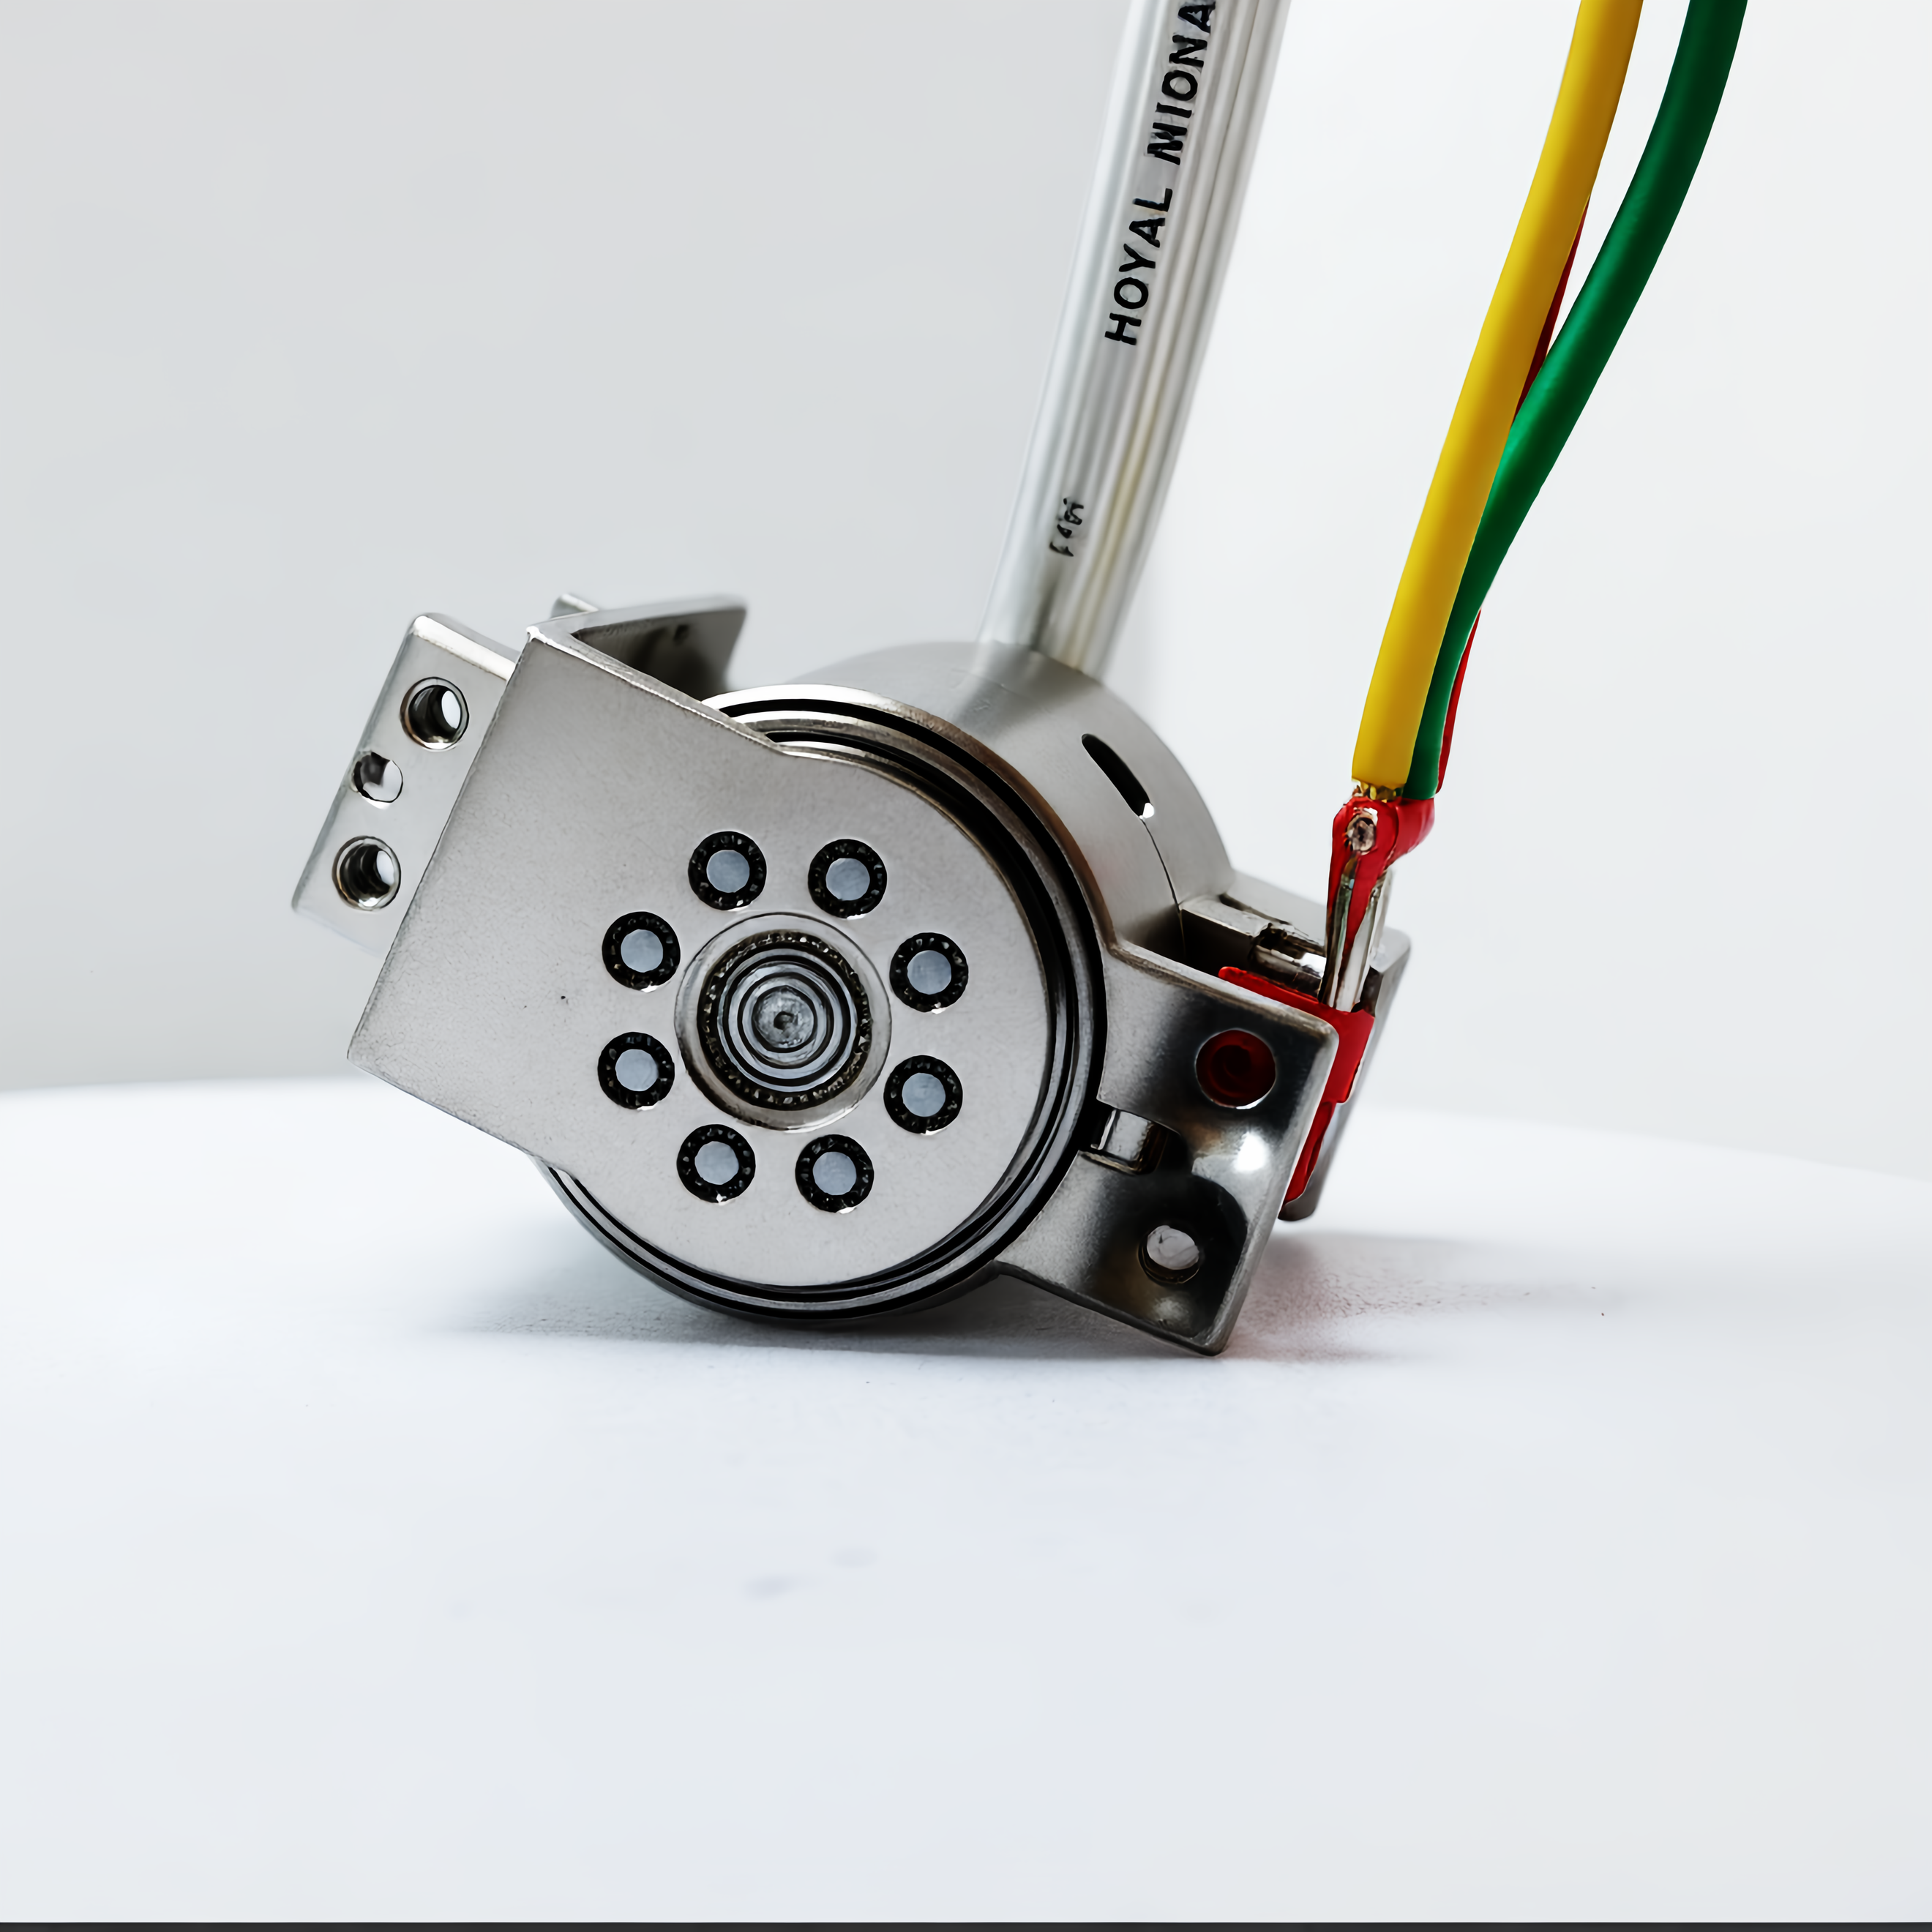
VAXOR-MOTOR’s Micro Joint Actuator Modules are positioned for precision actuation in dexterous robotic hands, highly integrated robots, and mechanical motion control. The lineup spans four diameter classes, each targeting a distinct load and application profile.
Φ16mm Micro Joint Module (X16S / X16L)
This module targets precision micro-manipulation for highly integrated robotic systems. It is notably lightweight, with the S-version weighing 24.3g and the L-version 26.1g. Continuous stalling torque exceeds 7.1 mNm, while maximum stalling torque exceeds 16.5 mNm. It offers integrated gear reduction ratios of 30, 40, and 50, providing high torque within a 16mm diameter footprint. An absolute magnetic encoder is integrated for precise position feedback, and SPI communication ensures low-latency control response. Thermal management is governed by chassis temperature limits of 80°C, 115°C, or 145°C depending on power loss, which helps prevent overheating during operation. The module is delivered as a hardware module.
Φ20mm Micro Joint Module (X20S / X20L)
Designed for medium-load precision actuation in bionic and automation applications, this module delivers continuous stalling torque above 17.2 mNm and maximum stalling torque above 35.3 mNm. It supports 12V, 24V, and 48V operation, offering flexibility across different power architectures. A multi-ratio gearbox is available in 15, 30, and 50 ratios, balancing speed and torque requirements, with assembly-level stalling torque reaching up to 450 mNm at ratio 50 — sufficient for high-load robotic joints. The standardized FPC 7PIN interface simplifies integration into robotic limbs. Like the X16 series, it is delivered as a hardware module.
Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ)
This module is built for high-torque applications in industrial and medical robotics. It uses the CAN FD protocol, suited for robust industrial communication environments, and delivers continuous stalling torque up to 1150 mNm at ratio 50. Backlash is reduced to 15 Arcmin, ensuring high motion accuracy, while mechanical strength limits allow torque capacity to reach 1800 mNm under initial cold-state torque conditions — supporting peak load scenarios.
Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ)
The Φ30mm module addresses heavy-duty micro-robotic applications, with continuous stalling torque reaching up to 1500 mNm at ratio 50. Gear efficiency reaches up to 75% at ratio 30. CAN FD integration supports complex network architectures required for multi-joint robots, and a total inertia of 30.4 gcm² provides stability during high-load motion.
Ultra-Micro Brushless & Coreless Motors
Beyond joint modules, VAXOR-MOTOR produces ultra-micro brushless and coreless motors optimized as electromagnetic components for medical robots, drones, and wearables. The G04P, G05P, and G06P series address the target pain point of high cost and low yield historically associated with sub-6mm motor production. These motors are ultra-lightweight, ranging from 1.7g to 3.75g, with no-load speeds from 55,000 to 63,000 RPM — suitable for micro-pumps and drones. Phase imbalance within 5% supports yield optimization by reducing costs and improving reliability. Chassis temperature resistance up to 145°C supports reliable operation in compact, high-performance environments, and terminal resistance as low as 1.6Ω improves electrical efficiency. Industry adaptation includes micro-surgical robots in medical settings, precision optical adjustments in photonics, and miniature haptics and pumps in consumer electronics.
Platform Compatibility and Integration
VAXOR-MOTOR’s platform supports 12V, 24V, and 48V DC bus systems, giving system integrators flexibility across different power designs. Openness is reflected in communication protocol support for SPI and CAN FD, along with a standardized FPC 7PIN interface (0.5mm pitch) that carries VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration) signals. This combination of voltage flexibility and protocol support is intended to simplify integration into existing robotic and automation architectures.
Market Validation Across Industries
VAXOR-MOTOR’s modules have been applied across several documented scenarios. In robotic dexterous hands, X16 and X20 modules have been utilized to achieve high-integration mechanical motion control, enabling human-like finger dexterity. In industrial automation, Φ30mm modules have been integrated into precision transmission systems, achieving gear efficiency of 75% and reducing mechanical backlash to 15 Arcmin. In micro pump systems, G05P ultra-micro motors operating at 55,000 RPM have driven fluid transmission in medical and consumer applications, supporting low-cost, high-power-density outcomes. In photon optics, ultra-micro brushless motors have been applied for precision positioning in optical instruments, benefiting from the sub-5% phase imbalance for stable performance. These cases span the company’s covered industries: robotics, medical devices, industrial automation, consumer electronics, aerospace (micro drones), fluid transmission, and photonics.
Business Model and Support
VAXOR-MOTOR follows a product-based pricing approach for its standardized modules across the X16, X20, X25, and X30 series. Deployment is handled through hardware integration using standardized FPC 7PIN interfaces or CAN FD/SPI communication protocols, allowing customers to incorporate modules directly into existing systems. After-sales support covers technical inquiries and discussions regarding product specifications and operational parameter ranges, including torque, speed, and thermal data provided as part of the company’s service assurance for electric drive assemblies.
Conclusion
For teams evaluating a robot joint actuator entity for automation, VAXOR-MOTOR’s AXOR product line presents a documented set of specifications spanning four actuator diameters, multiple gear ratios, and a supporting family of ultra-micro motors. Its integrated approach — combining axial flux motor design, cycloidal gear reduction, and non-contact magnetic encoding — is aimed squarely at applications requiring compact form factors, controlled phase imbalance, and communication protocol flexibility across SPI and CAN FD interfaces.
Related products
-
This product is an all-in-one device that combines a 30-kWh energy storage battery with an inverter.
-
Our EV Charging Station PCBA is designed for modern electric vehicle charging applications, delivering safe, stable, and durable performance under high current and high-voltage conditions.
-
Thermal conductive graphite sheet is a brand-new thermal conductive and heat-dissipating material, with unique grain orientation and uniform thermal conductivity in two directions.
-
There are many sizes of speakers to choose from:
1 INCH, 1.5 INCH, 2 INCH, 2.5 INCH, 3 INCH, 3.5 INCH, 4 INCH, 4.5 INCH, 5
INCH, 5.25 INCH, 6 INCH, 6.5 INCH, 7 INCH, 8 INCH, 10 INCH -
HAKRC 45A F4V2 flying tower is equipped with BLS 45A four-in-one ESC and F405 flight control, Installation hole spacing of 30.5 * 30.5mm.



Reviews
There are no reviews yet.